Garbage In, Modal Analysis Out: Five Setup Sins That Ruin Your Dynamics Run
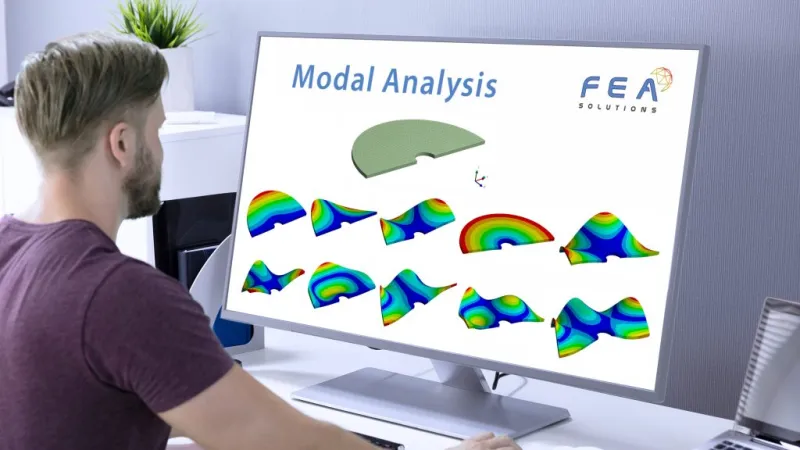
Photo: engineer reviewing finite element simulation modal analysis on computer screen, via fea-solutions.co.uk
Every simulation engineer has had the day: the modal run finishes, the first natural frequency comes back at 340 Hz for a bracket that visibly flaps in the wind, and everyone in the standup blames the solver. The solver is almost never the problem. The solver is a very literal-minded employee doing exactly what the model told it to do.
If your dynamics results feed a digital twin — and increasingly they do, since a twin with wrong modal content will mispredict vibration on the factory floor just as confidently as it mispredicts it in the solver — the errors compound downstream. Here are five setup sins worth auditing before you press 'Simulate' again.
1. The Fixture That's Actually a Weld
Symptom: First mode suspiciously high; mode shapes show almost no displacement at the mounts.
Fixtures get modeled as bonded contact or, worse, fixed constraints on every face that touches a bolt. In reality, a bolted flange is a spring — a stiff one, but a spring. Fully welding it adds phantom stiffness, and your frequencies come back 20–40% high. Your digital twin then predicts a machine that will never rattle, until the real one does.
Quick diagnostic: Delete the bonded contact at one mount and replace it with a bolt pretension plus frictional contact. Rerun. If the first mode drops more than 10%, your fixture was lying to you.
2. Missing Contact Definitions — The Parts That Pass Through Each Other
Symptom: Mode shapes that look plausible but a harmonic response that's way too soft; or, in the time domain, components visibly interpenetrating in an animation.
In assembly models, every interface defaults to something — often nothing. Two parts that merely sit adjacent in CAD have no relationship in the solver unless you define one. The solver assumes they're ghosts.
Quick diagnostic: Run a static gravity load case first. If parts that should bear load show zero stress at their interfaces, you've got undefined contacts. Most preprocessors will list auto-detected contact pairs; read that list like a flight manifest, not a formality.
3. Idealized Joints — The Hinge That's Actually a Clearance Fit
Symptom: Rigid-body modes where you expected elastic ones, or joint reaction forces that look absurd.
Idealized joints impose perfect kinematics: zero clearance, zero friction, infinite stiffness in the constrained directions. Real pin joints have slop, and slop dominates dynamics in mechanisms with any play in the load path. A digital twin built on idealized joints will predict smooth motion right up until the real machine hammers its own bearings.
Quick diagnostic: Check the joint's constraint directions against the actual fit tolerance. If the clearance exceeds 0.1% of the joint's travel, model it — bushing elements are cheap, and the frequency shift they introduce is usually the whole story.
4. The Mesh That's Fine for Statics and Useless for Dynamics
Symptom: Stress results looked great last month; today's modal results change 15% every time you refine.
Statics tolerates a lazy mesh. Dynamics doesn't, because stiffness errors shift frequencies directly. A coarse mesh overestimates stiffness — the mesh is, effectively, an extra truss welded into your structure.
Quick diagnostic: Run the same modal analysis at three mesh densities. If the first mode moves more than 2–3% between the last two, you haven't converged, and no post-processing will save you. Bonus check: verify element quality in thin regions, where a single element through thickness quietly turns a shell problem into garbage.
5. Damping: The Number Nobody Measured
Symptom: Resonant peaks in the frequency response that are either terrifyingly sharp or suspiciously flat — and no way to tell which is right.
Damping is the great guess of dynamics analysis. Most teams type in 2% modal damping because a textbook said so, and the resulting frequency response is only as honest as that guess. For a digital twin meant to predict real machine behavior, an unvalidated damping value is a decoration.
Quick diagnostic: If you have any experimental data — even a hammer test on a prototype bracket — back-calculate the damping from the half-power bandwidth. If you have nothing, run your response at 1%, 3%, and 5% and report the spread. A result with honest error bars beats a confident fiction every time.
The Upstream Habit
Notice the pattern: none of these are solver problems. They're translation errors between the physical machine and its model — and each one is cheaper to fix before the run than to explain after it. Build the audit into your preprocessing checklist, and the twin you publish to the factory floor will describe the machine you actually built, not the one the software imagined.