The Three Numbers That Move the Machine: A Pre-Solver Mass-Properties Audit
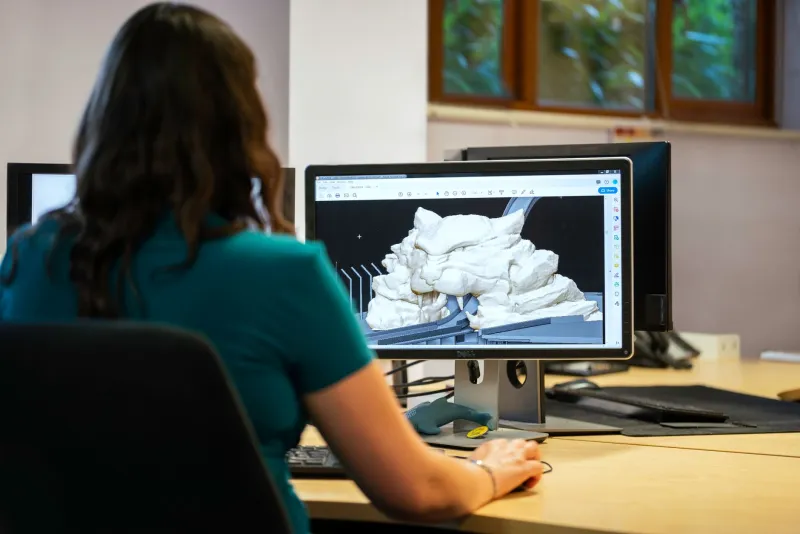
Multibody dynamics has a way of making small modeling choices look like physical laws. A bearing runs hot, a linkage oscillates at an unexpected frequency, or a mount sees a load spike that no test engineer can reproduce. The investigation often turns to damping, contact stiffness, or the test rig. Before that happens, it is worth checking the three numbers the solver inherited from CAD: mass, center of gravity, and the inertia tensor. They are compact, authoritative-looking, and easy to approve without reading.
That is the risk. A multibody model is only as trustworthy as the mass properties assigned to its bodies. A density left at the default, an origin placed at the wrong datum, or a paint layer omitted from the bill of materials can shift the center of gravity by a few millimeters. In a slow-moving assembly, that shift may be harmless. In a high-speed mechanism, it becomes a different bearing load, a different natural frequency, and a different set of conclusions. The audit described here is a 30-minute gate, not a research project. Its purpose is to catch the errors that a dynamics run will otherwise blame on something else.
The Solver Inherits What CAD Declares
CAD mass-properties dialogs are convenient because they are close to the geometry. That convenience also makes them easy to trust. The dialog reports a mass, a center of gravity, and an inertia tensor in the part or assembly coordinate system, usually with several decimal places. The solver accepts those values and builds equations of motion around them.
But the solver does not know how the values were produced. It does not know whether the density came from a generic steel library or a supplier datasheet. It does not know whether the part origin was chosen for modeling convenience or for assembly alignment. It does not know whether the modeler suppressed a connector, omitted a weld bead, or represented a bearing as a solid cylinder. Each of those choices is legitimate in CAD. Each becomes a hidden assumption in dynamics.
The audit should therefore begin with a simple premise: the solver is not receiving geometry. It is receiving a numerical summary of engineering intent. That summary needs an owner and a check.
Audit Density Before You Audit Geometry
Density is the quietest error in the chain. A part modeled in a generic material may carry a density that is plausible but wrong for the actual alloy, coating, or manufacturing process. A casting may be modeled as solid when the production part has cored pockets. A composite panel may use an equivalent density that bundles skin, core, and adhesive into one number. None of these choices is automatically incorrect, but each should be deliberate.
Start with a material cross-check. For each body that carries significant inertia, confirm the density source and its units. In US workflows, the unit risk is especially persistent: pounds-mass, pounds-force, slugs, and inch-based densities can coexist in the same project. A density entered as lbm/in³ instead of slug/in³, or a mass moment of inertia reported in lb·in·s² instead of lb·in², will not announce itself. It will simply produce a model that is off by a constant factor.
A useful second check is a hand calculation for one or two dominant bodies. A rectangular plate, a shaft, or a simplified housing can be estimated closely enough to reveal a gross unit error. The goal is not to replace CAD. The goal is to make sure the CAD number is in the right neighborhood before it becomes a solver input.
Put Every Body in the Right Frame
The inertia tensor is frame-dependent. That is why a mass-properties audit must confirm which coordinate system the solver will use and how the CAD value will be transformed. Part origins, assembly origins, and solver body frames are not interchangeable. A tensor reported about a part origin may need the parallel-axis theorem before it is valid about the center of gravity. A tensor reported about the center of gravity may need a rotation before it aligns with the solver body axes.
This is where many errors hide. The mass and center of gravity may look reasonable while the products of inertia are silently referred to the wrong axes. The resulting simulation may still run, but the body will respond incorrectly to angular acceleration. In a rotating assembly, that can corrupt bearing reactions and mount loads without producing an obvious instability.
A practical check is to record the frame convention for each body: the CAD reference frame, the solver body frame, and the transformation between them. If the model uses a mixture of part-origin and center-of-gravity tensors, document which is which. The audit should also confirm that the center of gravity is expressed in the same frame as the applied loads and constraints. A correct tensor in the wrong frame is still a wrong input.
Inventory the Mass That Geometry Leaves Out
CAD geometry is a partial description of a physical assembly. Fasteners, washers, weld beads, paint, labels, cables, fluid volumes, and balance weights all contribute mass. Some are modeled; many are not. A multibody model that ignores them can still be useful, but the omission should be intentional and recorded.
The audit should include a simple mass inventory for each body. Add up the modeled solids, then list the known omissions and estimate their effect. A few bolts may seem trivial until they sit at the end of a long arm. A paint system may be negligible on a bracket but meaningful on a large panel. A fluid-filled cylinder may have a center of gravity that shifts with operating condition.
This is also the place to check simplification choices. A bearing represented as a rigid cylinder, a spring represented as a point-to-point force, or a motor represented as a lumped mass all change the mass distribution. The question is not whether simplification is allowed. The question is whether the simplified mass properties still preserve the behavior the study is meant to predict.
Decide What Is Rigid, What Is Flexible, and What Is Neither
Multibody dynamics often begins with rigid bodies because they are efficient and stable. That assumption should be visible in the mass-properties audit. If a component is treated as rigid, its stiffness is effectively infinite, and its inertia tensor is the only structural information the solver receives. If the real part flexes enough to change load paths, the rigid assumption may be the dominant error, not the density.
A short rigid-versus-flexible review can prevent a long investigation. Identify the bodies whose deformation matters, the bodies whose mass dominates, and the bodies that are merely placeholders. For placeholder bodies, confirm that their mass and inertia are not accidentally driving the system response. A dummy body with a default density can become a flywheel the design never intended.
Compare the Tensor to a Second Opinion
The final step is a consistency check against something outside the CAD dialog. That second opinion can be a hand calculation, a previous program with known hardware correlation, or a supplier-provided mass-properties sheet. The comparison does not need to be exact. It needs to be close enough to expose a factor-of-ten unit error, a missing component, or a frame mistake.
Record the result in a short table: body name, mass, center of gravity, principal moments, frame convention, and source. This table becomes the audit trail for the multibody model. It also gives the dynamics engineer a defensible answer when a bearing load looks wrong. Instead of starting with damping, contact, or the test rig, the team can confirm that the bodies entering the solver carry the mass properties the design actually intends.
At MUDynamic, the interest is not in adding ceremony to simulation. It is in putting checks where they change the outcome. Mass properties are one of those places. The numbers are small, the dialogs are familiar, and the solver is patient. A 30-minute audit before the run is often the cheapest way to keep a dynamics investigation focused on the machine rather than on the model's inherited assumptions.